Plan routes.
Understand passages and obstacles.
 CoVista
UBC CAPSTONE CONCEPT · 2027
Collaborative drone mapping
for complex, GPS-denied spaces.
Seeking teammates & application partners
Explore ↓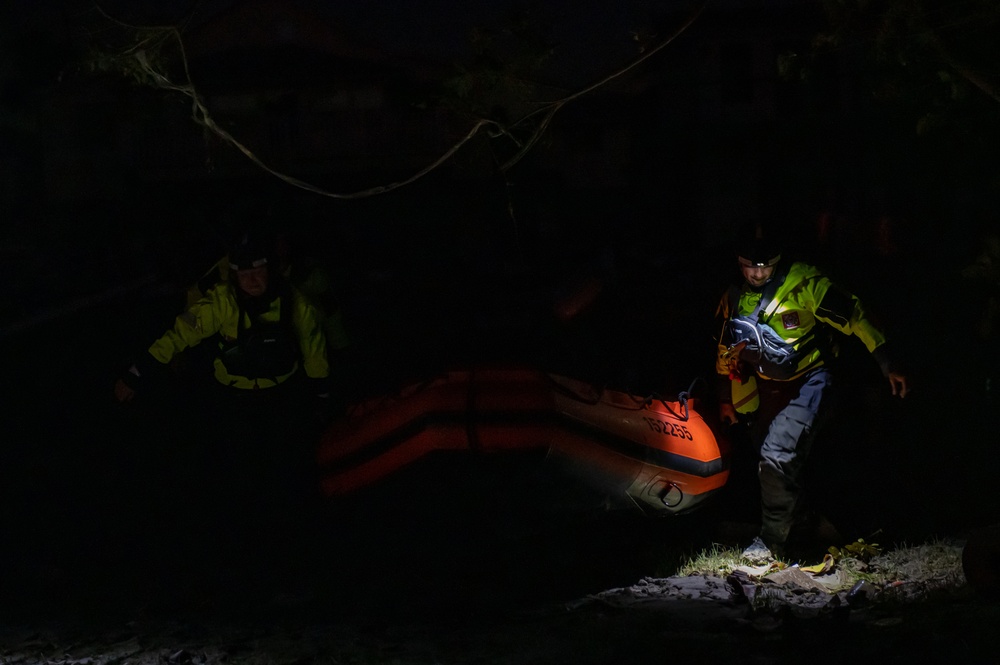
REAL CONDITIONS · RESEARCH GOAL
A shared picture of passages, obstacles and unseen areas—for planning before entry.
Why it matters ↓Night-response context · U.S. Coast Guard, 2022Our goal:
make complex spaces easier to understand.
Understand passages and obstacles.
Observe surfaces hidden from one pass.
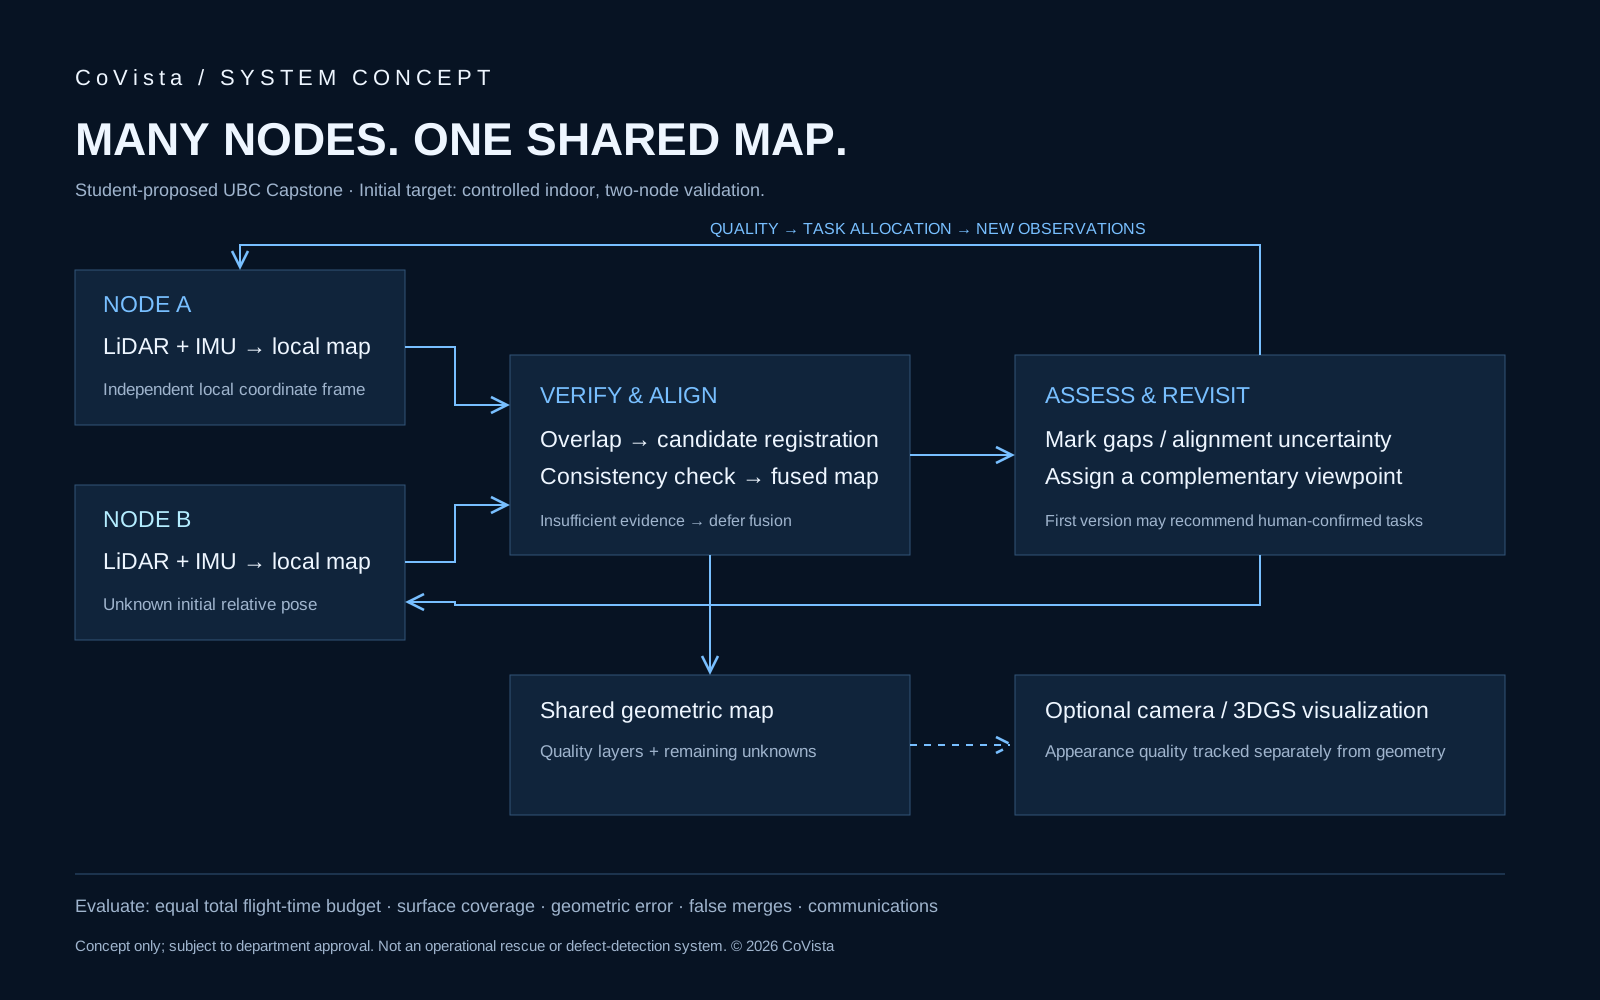
Combine observations and retain unknowns.
NIST's 3D mapping challenge addresses indoor, low-light and GPS-denied response.
Some detailed real-time intelligence tools can cost this much, NIST noted.
Read source ↗The SubT final scored-run window—not a CoVista flight-time claim.
Rules §8.3.7 ↗Start indoors: test map alignment and complementary observations.
How we test ↓NIST UAS 5.0 ↗External sources establish context. CoVista remains a Capstone research proposal.
START WITH MEASUREMENT
Compare collaboration with independent passes under the same combined flight budget.
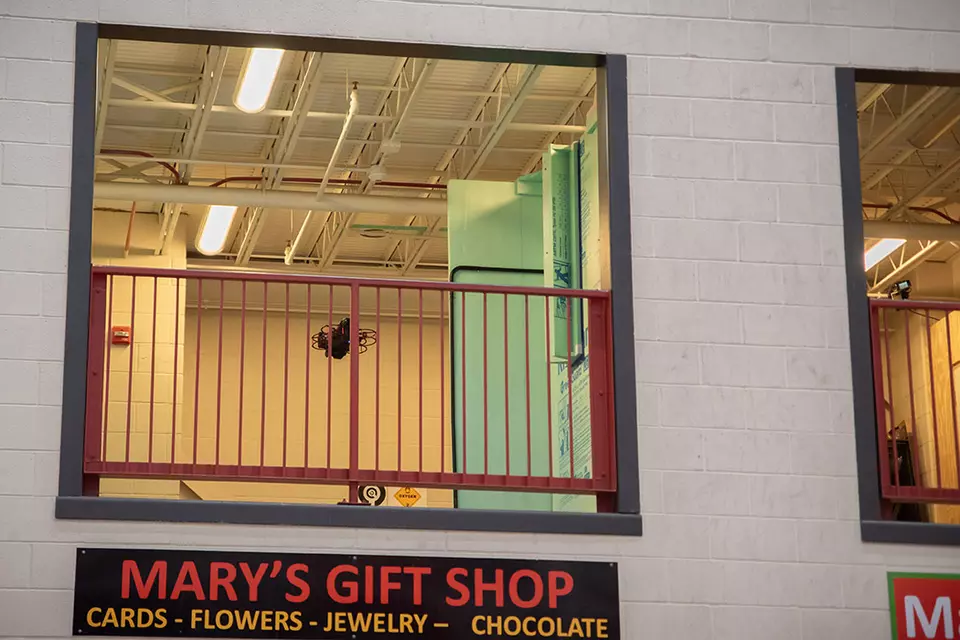
Photo-reference UAV. Simulated environment and scan.
Real-world context. CoVista has not been deployed at these sites.
Map passages and hidden corners.
Explore spaces without GPS.
See beneath decks and around supports.
Bring a challenge. Help shape the project.